Pipe inspector
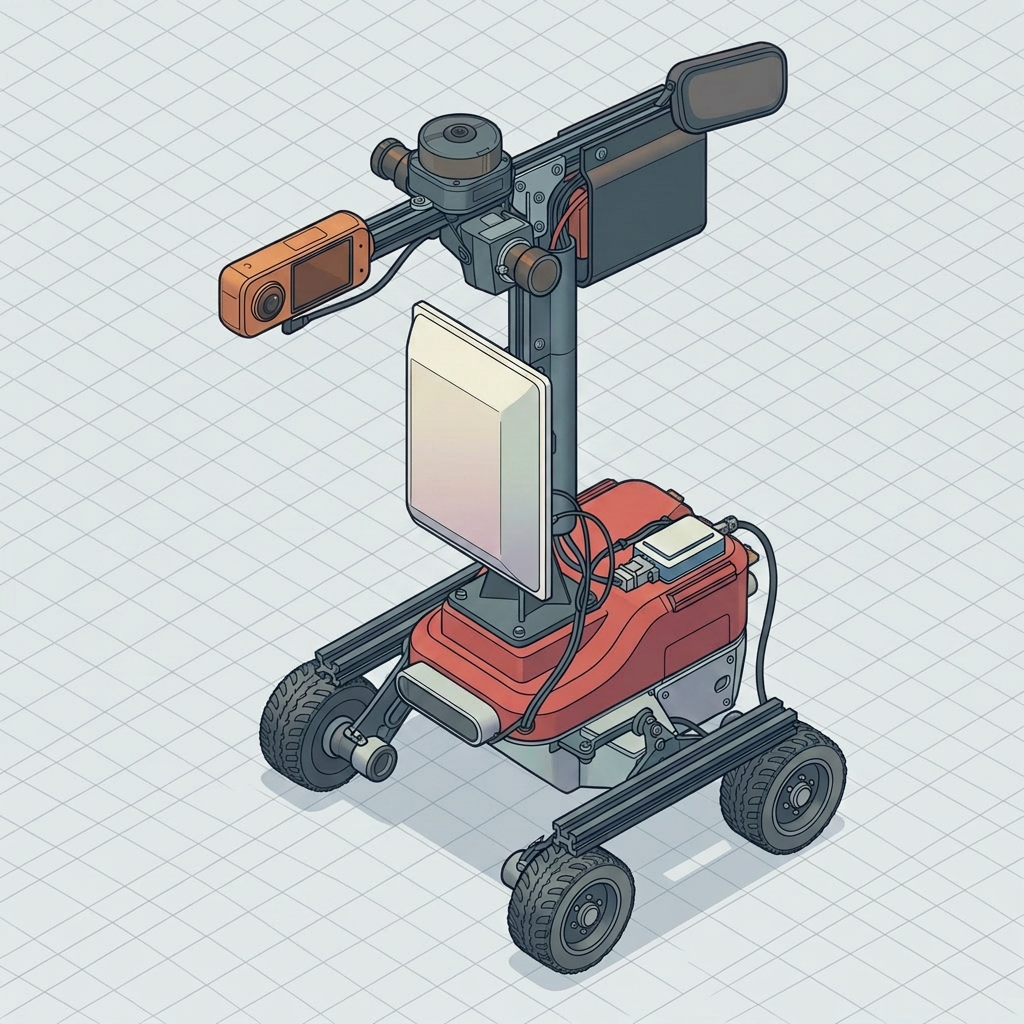
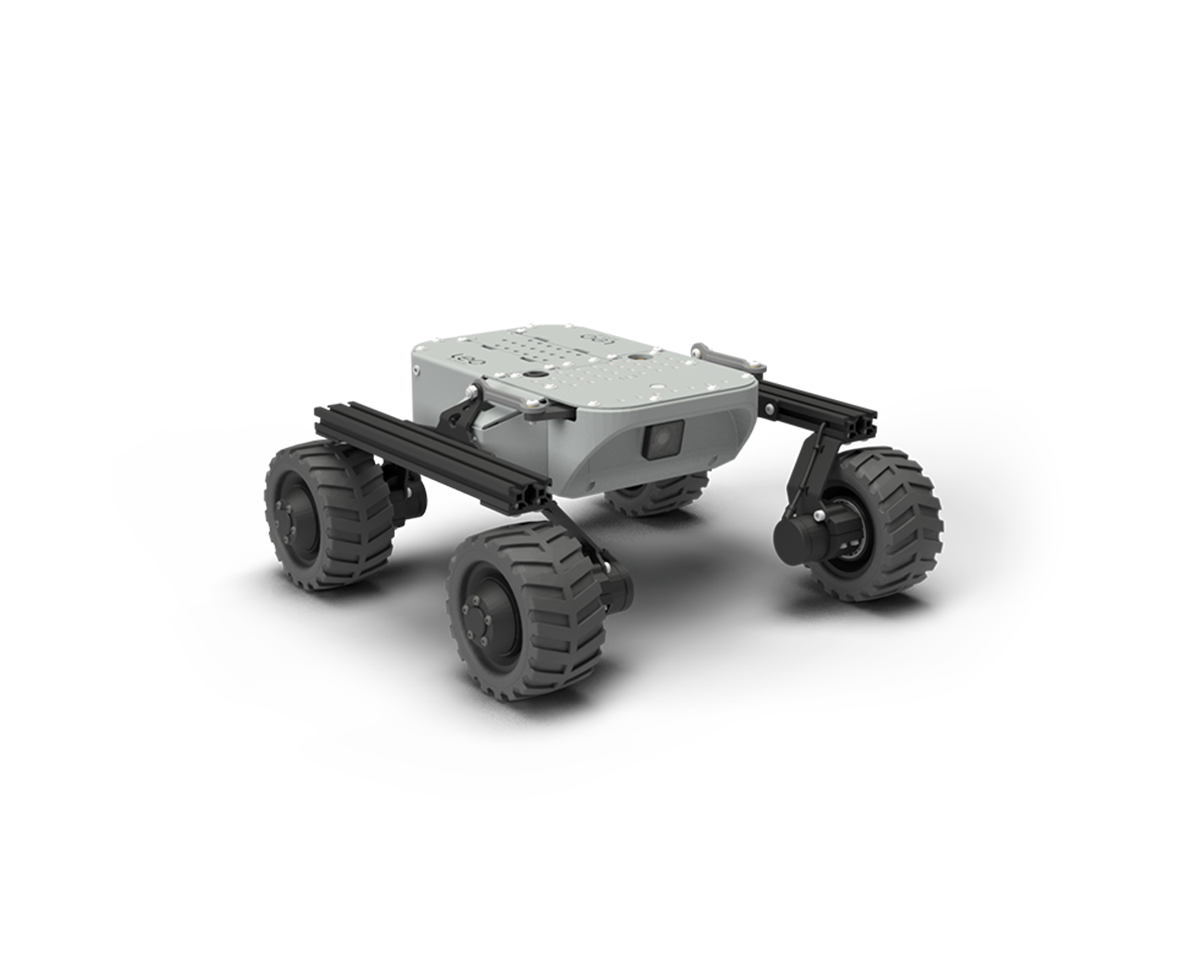
Pipe inspector (Pipe Seam Inspector) is the dedicated Karelics robot for measuring pipe joint gaps during tunnel and utility pipe installation. It is built on LeoRover. It is the only robot that supports the pipe seam inspection use case — Rhino inspector and other fleet robots do not run this workflow.
Platform
| Form factor | Compact pipe seam platform — 425 × 448 × 700 mm, 12 kg |
| Speed | Up to 14 km/h |
| Runtime | Up to 6 h total, 4 h driving per battery cycle |
| Sensors | 2× 4K (L/R), 360° Insta360, 2D LiDAR, UWB, adjustable pole |
| Standard kit | Robot · tablet with holder on pipe-laying machine · base station · extra batteries and charger |
Hardware capabilities
- 2D LiDAR for left/right gap measurement (mm)
- Dual 4K cameras and 360° Insta360 for joint and interior capture
- Re-localization after battery swap
- Falling avoidance and emergency STOP on Screen UI
- Manual teleoperation with multi-camera remote drive
Safety
- Worker stays outside the pipe during alignment
- Emergency STOP on the Screen UI dashboard
- Falling avoidance while driving inside the pipe
Solutions where this robot is used
📄️ Pipe seam inspection
Base platform
📄️ LeoRover
Related
- Pipe seam inspection — solution overview, operator guide, and Cloud workflow
- Brain Release 2026.28.0 — latest Pipe inspector Brain notes